

Description
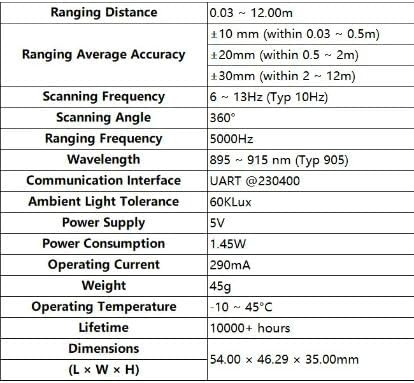
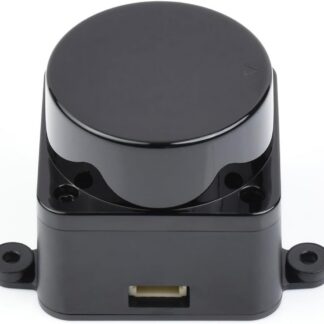
D500 LiDAR kit with 360-degree DTOF laser scanning for drones, robots, and 3D mapping. The rotating scanner sweeps a full circle and builds a live point cloud of everything around it, from 0.03m out to 12m, with accuracy of +/-10mm up close, +/-20mm at mid range, and +/-30mm at full range.
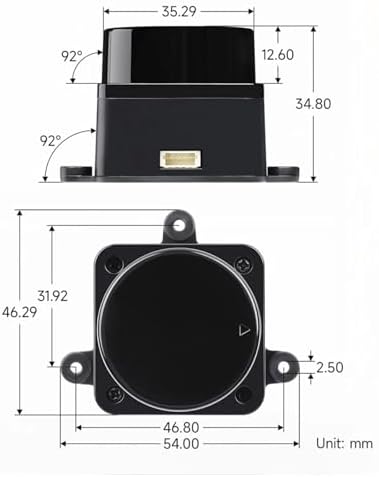
For drones, it adds real obstacle sensing and mapping to the airframe. At 45g and 54 x 46 x 35mm it mounts on a multirotor without eating your payload budget, runs on 5V at 290mA, and talks over UART at 230400 baud. Use it for obstacle avoidance, terrain following, aerial mapping, and inspection flights where the drone needs to see the world around it instead of flying blind.
For robotics, it is a SLAM-ready sensor for navigation, obstacle avoidance, AGV guidance, and indoor mapping. The scanner runs at 6 to 13Hz (typically 10Hz) with a 5000Hz ranging rate, a 905nm laser, and tolerance for bright ambient light up to 60KLux. Rated lifetime is 10000+ hours, and it works from -10 to 45C.
Specs: ranging distance 0.03 to 12m; scanning angle 360 degrees; communication interface UART at 230400; power supply 5V; power consumption 1.45W; operating current 290mA; weight 45g; dimensions 54.00 x 46.29 x 35.00mm; operating temperature -10 to 45C; lifetime 10000+ hours.
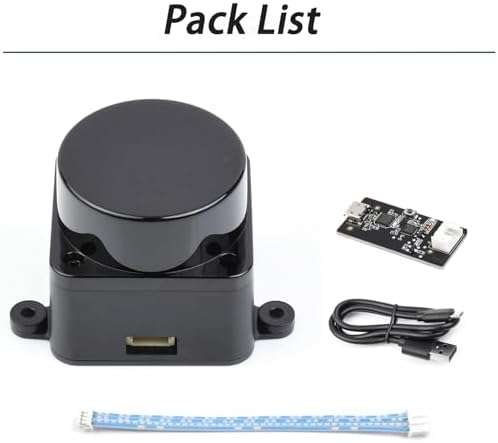
Kit includes: D500 LiDAR unit, adapter board, USB cable, and ribbon cable.
Shipped fast and securely from our secure facility in New York, providing fast, high quality USA shipping.
Reviews
There are no reviews yet.